Chi-Nguyen Tran
I’m a final-year B.Sc. student in Artificial Intelligence at VNUHCM, University of Science (HCMUS), and AI R&D Lead at Realtime Robotics.
I am doing research in robotics. My goal is to help robots understand what is around them, know where they are, and work out how to act, and whether it is safe to act, when their surroundings change. In the real world, light, weather and surroundings keep changing and sensors get noisy, so a model that scores well on test data can still fail once deployed. I work on models that hold up in those conditions and are light enough to run on the small computers robots carry:
- Perceive and localize. Robots that keep recognising where they are when the weather and the scene change.
- Act. Agents that act reliably on camera input distorted in ways they never saw in training.
- Test. Finding the road scenarios most likely to break a self-driving car.
- Next. Teams of robots that learn whom to trust, and vision-language-action models for acting on what they see.
I am looking for PhD positions starting Fall 2027 in robotics.
News
- 5 papers accepted at NeurIPS 2026 (Sydney), 2 as co-first author.
- Awarded the Vallet Scholarship 2026.
- Winner, FSE-AIWare 2026 Agentic Python Dependency Resolution Competition (MEMRES).
- Joined Realtime Robotics as AI R&D Lead, working on perception and localization for robots on embedded hardware.
- 1st Place in both tracks, NeurIPS 2025 Mouse vs. AI Robust Foraging Competition.
Selected Publications
* equal contribution
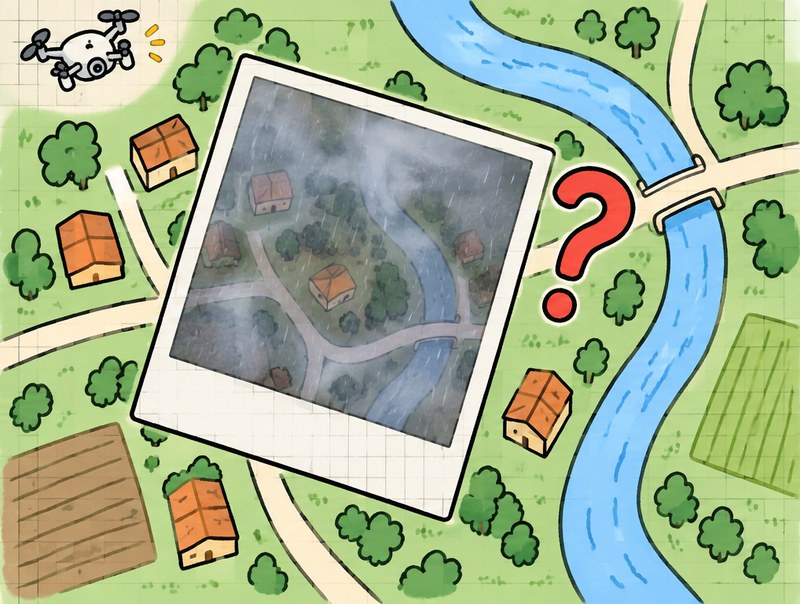
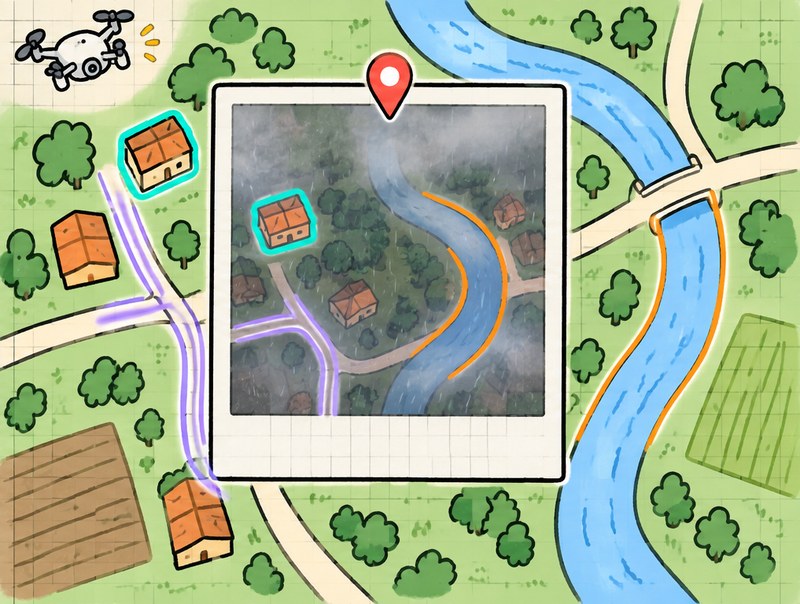
SkyPart: a lightweight prototype-based semantic-part head on a DINOv2 ViT that matches drone views to satellite tiles under fog, rain, snow and darkness. State of the art on weather-robust drone-to-satellite geo-localization with the fewest parameters among top methods.
MEMRES: A Memory-Augmented Resolver with Confidence Cascade for Agentic Python Dependency Resolution
Winner, FSE-AIWare 2026 Agentic Python Dependency Resolution Competition
An agentic resolver that repairs broken Python environments with a self-evolving memory, a confidence cascade over version candidates, and a build-and-reflect loop.
Streaming decision trees that learn new classes online from a data stream, with split decisions backed by a McDiarmid concentration bound and knowledge inherited across splits.
Holistic training with a slot-attention router, then compositional inference that scores queries part by part, so a continual few-shot learner generalizes to unseen combinations of known parts.
Aligns a frozen LLM to the moral preferences of a country without training: country-conditioned personas vote, and only the decisions they agree on are kept.
The benchmark paper of the NeurIPS 2025 Mouse vs. AI competition, co-authored with the organizers as a member of the first-place team.
Honors
- 1st Place (both tracks), NeurIPS 2025 Mouse vs. AI Robust Foraging Competition
- Winner, FSE-AIWare 2026 Agentic Python Dependency Resolution Competition
- 1st Place in five shared tasks at SemEval-2026, LREC 2026 and EACL 2026
- Third Prize, Vietnam Student AI Olympiad, National Round 2025
- Vallet Scholarship 2026
Service
- Reviewer: ACL, CVPR Workshops